Camera Rig

Client work
Delivered in 45 days
01 / Problem

A motorised rig that pans a device, and does it the same way every time.

02 / Brief

Hold any device up to 200 × 200 mm in portrait or landscape. Sweep 0-160° accurately. Be operable by test staff with no training. 45 days, design to delivery. ~200 units.

03 / Where the problem lives
AdaptabilityOne clamp holds every device configuration without re-engineering the base.
PrecisionSweep accuracy has to hold across 160° under fatigue. The hardest requirement.
RepeatabilityTolerance variation cannot compound into sweep error across 200 units.
DFMEvery decision had to survive the move from one prototype to a 200-unit batch, no re-tooling.
04 / Question

What does “accurately, repeatably” mean when the brief never set a speed?

05 / Derived

Speed was undefined at brief stage - no target value existed. After live demo sessions, three tiers - slow, default, fast - were validated with the client and locked in as the production spec.

06 / System
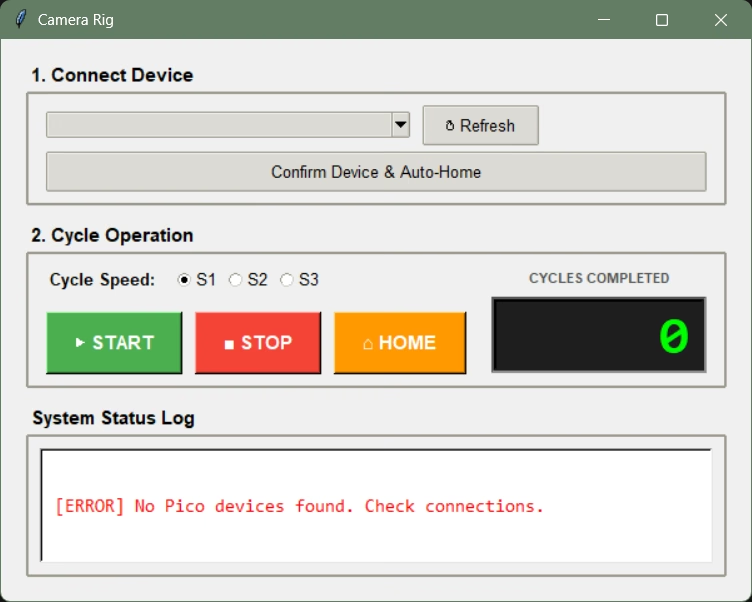
GUI applicationPython app. Select device, set speed, hit run. No CLI.
MicrocontrollerRPi Pico W, MicroPython - the Python stack matched the client requirement.
Stepper driverTMC2209. Compact, silent, sustained load over long test cycles.
MotorNEMA 17, chosen from load calculations. Servos failed precision and control tests.
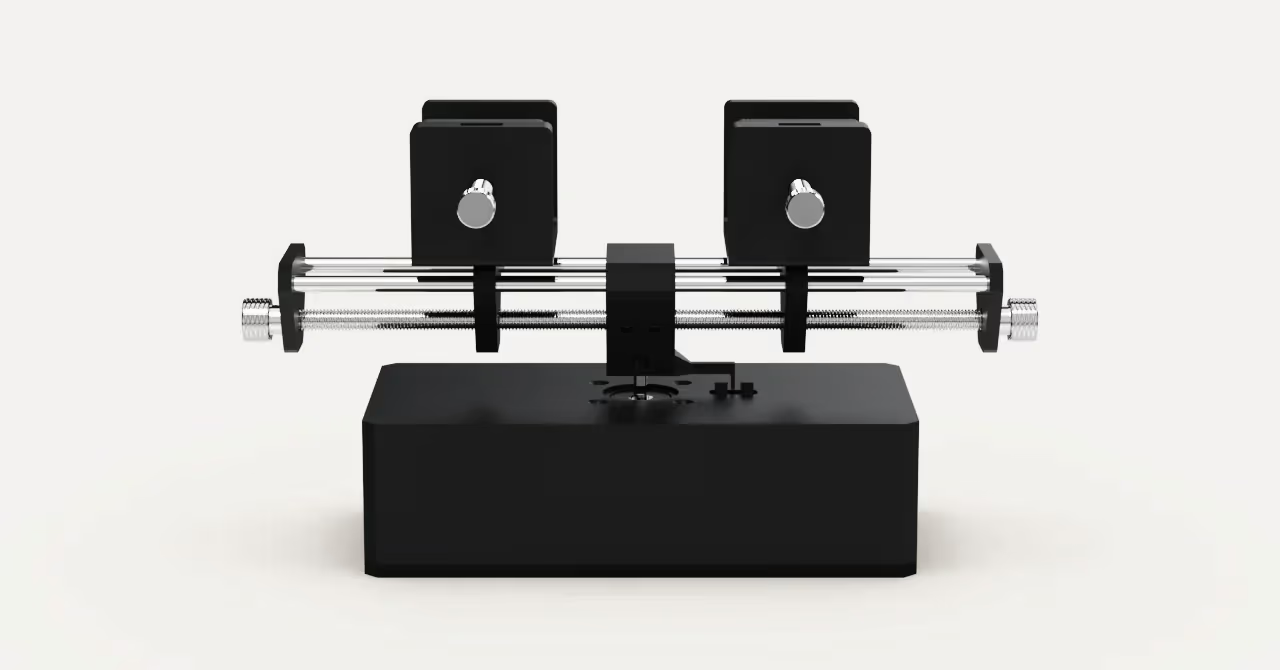
MechanismSelf-centering DUT clamp. Holds 0-200 mm, portrait or landscape.
07 / Decision

The clamp moves. The motion does not change.

08 / Consequence

Every variable - size, weight, orientation - is absorbed by the clamping mechanism. The motion platform, control software and sweep accuracy stay constant. The clamp carries the complexity so the system does not have to.
09 / Control software
The delivered Python control application - connect, choose a cycle speed, run
Delivered control software - connect, choose a cycle speed, run. No command line, no manual setup.
10 / Test
Sweep accuracy - full range under fatigueComplete
Repeatability - across unitsComplete
Operability - untrained staffComplete
BatchPending
11 / Result

One clamp, engineered to absorb every variable, so the motion and the accuracy stay constant whether the batch is one unit or two hundred.
12 / Real world
The finished rig - a self-centering clamp on a fixed motion base
The finished rig - a self-centering clamp on a fixed motion base, built to hold any device the brief specified.